Dristy
দৃষ্টি — a camera that answers with a number, not a video stream.
 SOURCE — github.com/fh1m/Dristy
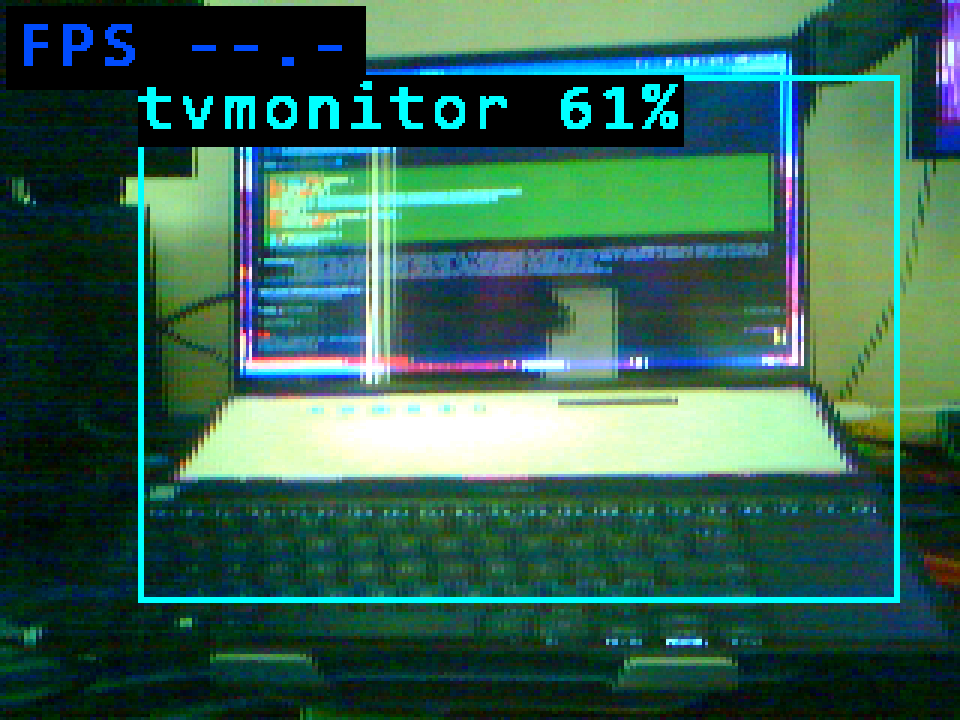
Open firmware and a host API for a Kendryte K210 camera that does vision on-device — so a robot gets a compact answer (“object at error_x, error_y”) over USB serial instead of a raw video stream. Tiny neural nets on the KPU plus classical vision (colour, line, motion, QR, AprilTag) on the RISC-V cores.
The idea is bandwidth and honesty. A microcontroller robot cannot carry a Pi and a GPU, and it does not need to: most of the time it only needs to know where the thing is, as an error to drive toward. Dristy turns light into that number on the sensor and sends four bytes, not a frame.
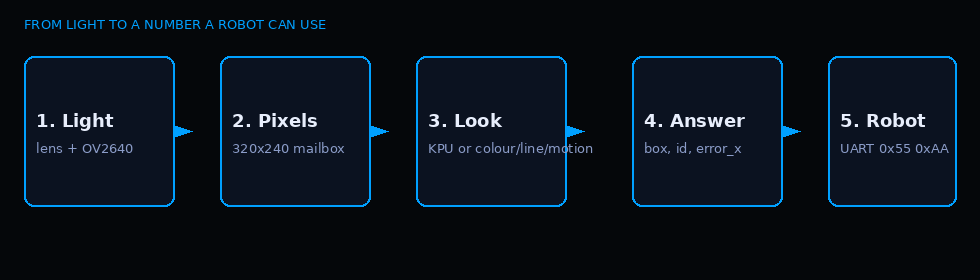
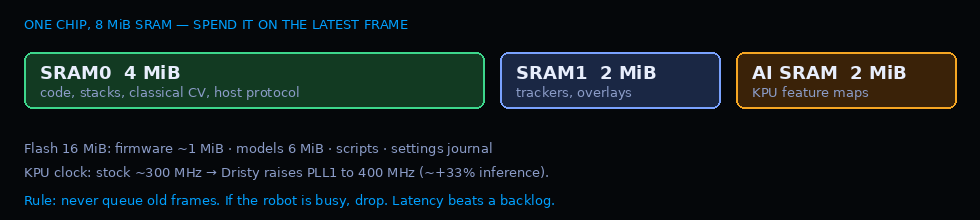
The whole design is a budget problem — the K210 has kilobytes of SRAM, so every model and buffer is placed by hand. The docs draw the “light to a number” pipeline and the memory budget, because on a chip this small the budget IS the architecture.