05 — About
One question, asked
in three mediums.
I’m Fahim — an autonomy engineer from Dhaka. I started where machines are hardest to hide: something that has to leave the ground. Rockets taught me guidance and control; rovers taught me manipulation and vision; underwater vehicles taught me to trust nothing I hadn’t measured. The thread through all of it is the same question — how does a machine understand the world well enough to act in it?
Today I build the whole stack: the firmware on the board, the estimator that fuses cheap sensors, and the neural net that sees. I care about the seam between software and physics — the place where an elegant idea meets a vehicle that either moves or doesn’t.
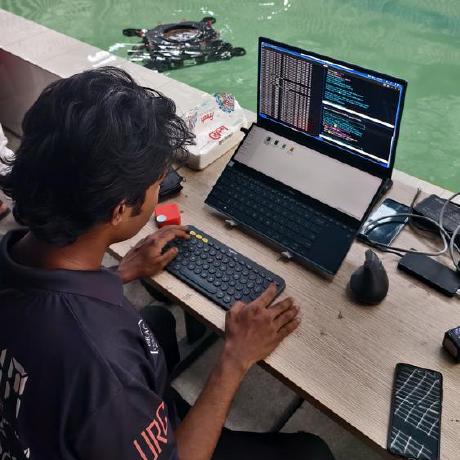
Muhammad Fahim Faisal
Autonomy & robotics engineer
- LOCATIONDhaka, Bangladesh
- FOCUSAutonomy · robotics · ML
- STATUS● Open to autonomy / robotics / ML roles
// experience
BRACU Duburi
Team Lead — Engineering · former Sub-Team Lead, AI & Machine Vision
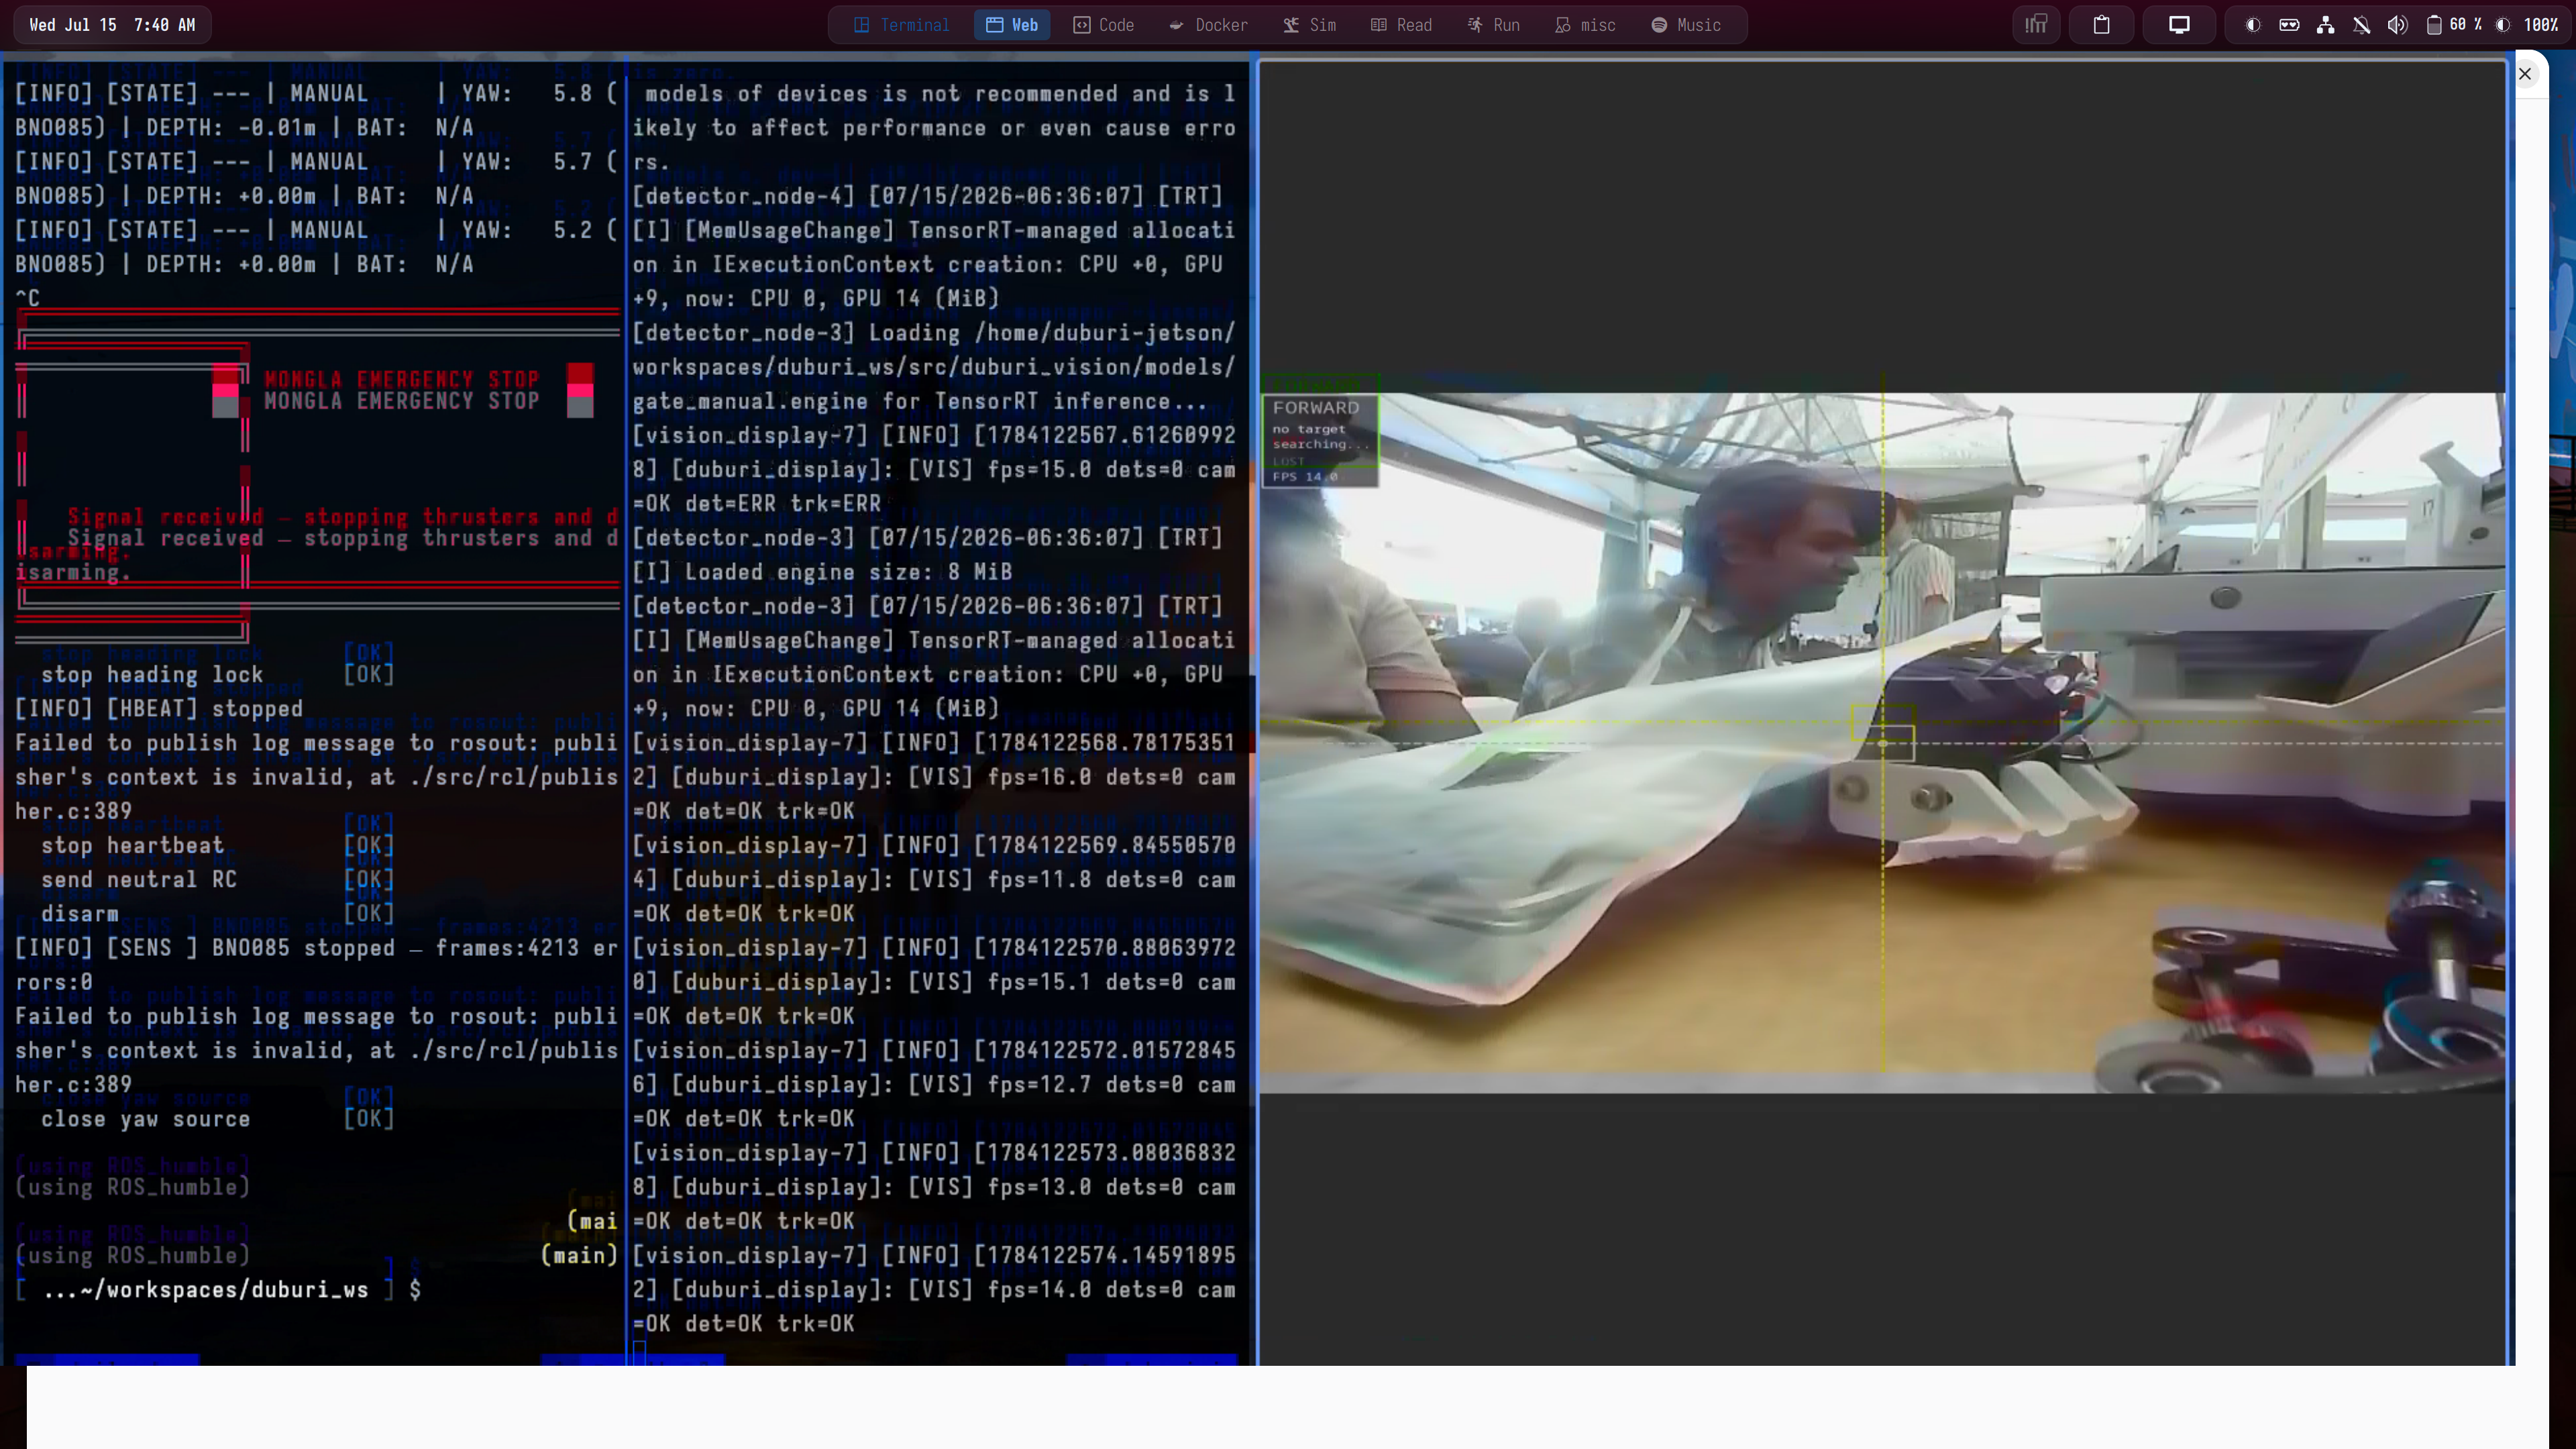
Oct 2023 — Sep 2026 Dhaka- Rebuilt the vision stack on state-of-the-art CNN architecture with a custom dataset pipeline.
- Created a training pipeline that streamlines custom models with advanced hyperparameter control.
- Integrated Domain-Specific Pretraining and Source-Free Domain Adaptation.
- Deployed on edge devices for efficient on-vehicle inference.
- Built in-house dev tooling for management and deployment.
BRACU Mongol-Tori
Contributor — Autonomous Subteam
Dec 2024 — May 2025 Dhaka- Implemented inverse kinematics for a 2-DOF arm for autonomous typing tasks.
- Built and deployed a lightweight vision unit for arm alignment, separate from the rover.
- Wrote custom OCR + image processing to identify and differentiate keys.
- Built an in-house GUI and sim environment for calibration and early testing.
- Managed the dataset pipeline for URC 2025.
Amateur Experimental Rocketry (AERD)
Core Member — A&GNC, Trajectory Prediction, Parachute & Procurement
Feb 2023 — Feb 2025 Dhaka- Implemented a ROS 2 (Humble) stack for data acquisition.
- Worked with flight controllers (Pixhawk, Betaflight); led V1 of an in-house flight computer for a monocopter UAV.
- Worked on a VSLAM software stack for GPS-denied autonomous navigation.
- Ran trajectory prediction with RocketPy against real flight-test data.
BRACU Rocketry — LASSET Lab
Sub-Team Member — Controls & Trajectory Prediction
Sep 2024 — Feb 2025 BRAC University- Built an in-house PID controller for a TVC gimbal; submitted the demo to the Research Excellence Awards Initiative for funding.
- Implemented a 2-axis controller.
- Built a custom GUI for tracking and monitoring.
Dubotech
Jr Autonomous Engineer
Oct 2025 — Feb 2026 Dhaka- Developed custom firmware for sonar tech.
- Created a navigation stack for deep-water monitoring.
- Built and maintained backends for the sonar stack; started in-house tooling documentation.
Thinkit Inc
Web Dev Intern
Mar 2021 — Jun 2021 Dhaka- Wrote back-end code for a transition to MongoDB.
- Fixed front-end bugs.
ICT Club — SOS Hermann Gmeiner College
General Secretary
Jan 2022 — Sep 2022 Dhaka- Ran the club end to end — seminars, programs, operations.
- Automated content management with the YouTube / Facebook APIs.
// education
BRAC University
BSc Computer Science — Minor: Electrical & Electronic Engineering
Currently in the 6th semester.
IU International University of Applied Sciences
BSc — Autonomous Systems
One semester, on campus.
ten people, one reflex each
 b. 1989
George Hotz
geohot · tinygrad, comma.ai“Complex things eventually collapse under their own weight.”
Research, with my name on it.
Color is Also Class Evidence: Re-evaluating Domain Generalization for Underwater Object Detection
Advanced vision systems for AUVs — tested against the RoboSub 2025 / 2026 footage.
READ THE PAPER ↗E-Commerce Recommendation System Based on Demand Clues
Recommendation systems to improve customer experience, with an international group of researchers.
READ THE PAPER ↗A short list of things I believe, and keep testing against the machine.
- 01 I like machines that have to deal with reality.
- 02 I like understanding what sits beneath the abstraction.
- 03 I like taking expensive or opaque systems apart and rebuilding them from first principles.
- 04 I like robotics because there is nowhere to hide: eventually the machine has to move.
- 05 I like software because it lets an idea become behavior.
- 06 I like hardware because physics gets the final vote.
- 07 I like open source because knowledge should compound.
- 08 I like difficult problems because they expose what I don’t understand.
- 09 And I am still building.